
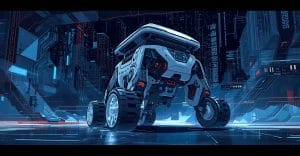
Boston Dynamics swapped Atlas’s feet for scooter wheels to test whether AI-trained robot behaviour learned in simulation holds up on real hardware.
Imagine a humanoid robot built for factory floors, stripped of its feet and fitted with a pair of off-the-shelf scooter wheels — then sent rolling at speed to find out whether its artificial brain can keep up with its body. That is essentially what Boston Dynamics has been doing with its Atlas robot, and the results offer a fascinating window into how close we are getting to robots that can genuinely think on their feet. Or, in this case, their wheels.
Boston Dynamics posted details of the experiment, showing Atlas moving on two wheels mounted where its feet would normally be — accelerating, braking, turning and sliding sideways, all controlled by software trained through reinforcement learning.
Off the Shelf, Onto the Robot
The engineering behind the modification is surprisingly straightforward. Boston Dynamics explained that a single custom adapter mounts an off-the-shelf scooter rim onto the existing ankle actuator, and that’s the only new part in the whole build. So the rest of Atlas — the legs, the torso, the arms, the computing stack — remains exactly as it was. Only the contact point with the ground has changed.
On the software side, the team took an equally elegant approach. Each wheel is simply modelled as an “ankle” that can spin continuously, so all they had to do was take the baseline robot model and swap the feet out for wheels. That meant the underlying control system, which was already designed around Atlas’s ankle joints, could be adapted without rebuilding everything from scratch.
Teaching a Robot in a Virtual World
To understand why this matters, it helps to know a little about how modern robots learn to move. Reinforcement learning is a training method where software runs through millions of simulated trials — the robot attempts a movement, gets a score based on how well it did, and gradually improves. Think of it like learning to ride a bike, except compressed into thousands of virtual hours rather than scraped knees over a summer.
The challenge is what researchers call the “sim-to-real gap.” A simulation is a model of the world, and models are never perfect. A virtual motor might behave more cleanly and predictably than a physical one that heats up, wears down, or hits mechanical limits. So the question Boston Dynamics set out to answer was a pointed one: the goal of this project was to see how faithfully a learned whole-body controller can work with real actuators, especially when they’re running at the edge of their performance envelopes.
Wheels made that test above all demanding. Unlike walking, where each step involves a brief pause, wheels demand continuous, precise control. High-speed rolling, sharp turns and sudden stops all push actuators hard. If the simulation had taught Atlas bad habits — movements that looked fine in the virtual world but overstressed the real hardware — this test would expose them.
Not a Product. A Research Platform.
It is worth being clear about what this is and what it isn’t. Boston Dynamics has described the wheeled Atlas as a research configuration, not something heading to market. The company is owned by Hyundai Motor Group, and Atlas is being developed as an electric humanoid robot aimed at industrial settings — warehouses, assembly lines, environments where physical labour is repetitive or hazardous.
But this wheeled experiment sits outside that commercial roadmap. It is an engineering tool: a way to stress-test the relationship between simulated training and real-world performance, using a configuration that pushes the hardware to its limits in ways that standard bipedal walking might not.
That distinction matters. Demonstrations of robots doing impressive things can sometimes outpace the reality of what is actually available or deployable. What Boston Dynamics is showing here is rigorous engineering research, not a product launch.
Why Accurate Simulation Matters So Much
One of the quieter but more consequential parts of this project is the work done on actuator modelling. To close the sim-to-real gap, the team worked on making the virtual version of Atlas’s motors behave more like the physical ones — including their limits, their heat behaviour, and their responses under load.
This kind of work is unglamorous but essential. A robot that performs beautifully in simulation but fails unpredictably in the real world is not useful. And for industrial applications — where Atlas might be working alongside people on a factory floor — reliability is everything.
So while the wheeled Atlas rolling around a test space might look like a party trick, the engineering underneath is serious work on one of the hardest problems in robotics.
What This Means for Kent Residents
There’s no direct local angle here — Boston Dynamics isn’t testing wheeled Atlas in Sittingbourne or rolling it through a logistics park in Dartford just yet. But for anyone working in Kent’s manufacturing, warehousing or logistics sectors, the broader direction of travel in humanoid robotics is worth watching. As companies like Boston Dynamics move closer to deployable industrial robots, UK workers and employers alike will need to think about how automation fits into the future of those industries.
Source: @BostonDynamics
Boston Dynamics Fits Atlas Humanoid Robot With Wheels to Push Reinforcement Learning to Its Limits Quiz
5 questions